About Me

I am a Robotics and Machine Learning Engineer with experience across autonomous vehicles, perception, computer vision, robot learning, simulation, and real robot deployment. I enjoy building intelligent systems that connect scene understanding and learned models to reliable behavior in the physical world.

My current interests are in Embodied AI, multimodal learning, VLMs/VLAs, imitation learning, reinforcement learning, and post-training methods such as SFT and RLHF. I am especially interested in how these approaches can improve scene understanding, policy learning, generalization, and decision making in autonomous systems.

My background spans the full autonomy stack — from simulation, motion planning and controls to perception, sensor fusion, ML/DL, model evaluation, and deployment — which gives me an end-to-end view of how autonomous robots are built and evaluated.

Skills & Focus

ProgrammingPython, C++, C, MATLAB, Bash

ML / AIPyTorch, TensorFlow, Hugging Face, LeRobot, W&B, ONNX, TensorRT

Robotics / SimulationROS/ROS2, Isaac Sim, MuJoCo, CARLA, Gazebo, CarMaker

SystemsLinux, Docker, AWS, Git CI/CD, CUDA

Focus AreasRobot Learning, VLA/VLMs, Computer Vision, Perception, Sensor Fusion, Reinforcement Learning, Motion Planning & Controls

Work Experience

Sep 2025 – Present · California, USA

Toyota Research Institute: Senior Software Engineer — Machine Learning

Tools: Python, PyTorch, ROS2, LeRobot, Isaac Sim, MuJoCo, ONNX, W&B, Hugging Face, Docker, AWS, Git CI

  • Built large-scale ML evaluation and inference pipelines for autonomous-driving and robotics models, including Git CI-integrated distributed evaluation and ONNX/Git-SHA reproducibility.
  • Developed SmolVLA model-hosting and evaluation harnesses through LeRobot across Isaac Sim, MuJoCo, CALVIN, LIBERO, and RoboCasa, with Rerun and W&B diagnostics for policy rollouts.
  • Worked with the VLA Foundry ecosystem and gained exposure to production-scale LLM → VLM → VLA training and evaluation, including SFT/PEFT, RLHF-based reward-model improvements, teacher-student distillation/FSDP, CPT, and sim-to-real evaluation.
  • Developed multi-camera perception tooling and worked with BEV-based scene representations and intent prediction for autonomous-driving behaviors including pull-over and inactive-vehicle detection.

TRI public research demo · company context. Source ↗
Oct 2023 – Sep 2025 · California, USA

neuro42: Robotics & ML Engineer

Tools: C++, ROS2, Python, OpenGL/GLSL, PyQt, Isaac Sim, PyTorch, NI-DAQ, PLC, Linux

  • Led a cross-functional robotics team taking a pneumatic surgical robot from a 2-DOF proof-of-concept to a 6-DOF MVP within eight months.
  • Developed forward/inverse kinematics, waypoint trajectory generation, real-time control for pneumatic actuation, and encoder/PLC feedback validated on physical hardware.
  • Built a ROS2 hardware-in-the-loop digital twin and contributed across the complete robot software stack, from 3D visualization and Qt interfaces to backend hardware communication.
  • Worked on 3D MRI reconstruction, co-registration, and anomaly detection using 3D U-Net for brain imaging.

neuro42 official product animation · company context. Source ↗

Feb 2022 – Oct 2023 · Maryland, USA

Forterra: Perception Engineer

Tools: C++, ROS, Python, OpenCV, CUDA, TensorRT, Ceres Solver, Jetson Xavier/Orin, AWS

  • Developed intrinsic and extrinsic sensor-calibration pipelines for cameras, LiDAR, and RADAR using ICP and RANSAC, including a multi-camera calibration GUI and automated validation workflows.
  • Built sensor-fusion and localization functionality using EKF, improved AMCL localization, and developed multi-obstacle track management.
  • Worked on camera/LiDAR perception including homography-based trailer-angle estimation, LiDAR projection, semantic segmentation, camera ISP/image-quality testing, and GStreamer latency analysis.
  • Applied mixed-precision TensorRT optimization and deployed a DenseNet-UNet semantic-segmentation model on Jetson hardware.

Forterra: ADAS Simulation Engineer

Feb 2022 – Jul 2022 · C++, ROS, CarMaker, TruckMaker, OpenDRIVE, OpenStreetMap, SIL/HIL

  • Developed high-fidelity autonomous-vehicle simulation environments using satellite imagery and topography data and converted road/map formats into OpenDRIVE and OpenStreetMap.
  • Integrated LiDAR and ground-truth sensor models with ROS for SIL/HIL testing and autonomous-vehicle simulation.

Forterra public vehicle demo · company context. Source ↗
Robotics project demonstration

September 2021 - Feb 2022

Thordrive: Motion Planning Engineer

Location: OH, USA

Tools: ROS, C++, Eigen Lib, Dijkstra, KD-Tree, Rviz

  • Developed Route Planner stack for Autonomous vehicle, its simulations on Rviz and Performing tests on real vehicle
  • Implemented Adaptive destination selection for reference planning and develop planning stack diagnosis system
  • Tuning Lookahead distance for pure pursuit and Stanley Controller and test on Thordrive vehicle
Website Overview-Video
Robotics project demonstration

July 2021 - Sept 2021

Midea Group Emerging Technologies: Robotics Navigation Engineer

Location: CA, USA

Tools: Python, Raspberry pi, Pycoral TPU, Linux, Tensorflow

  • Midea Group Emerging Technologies is a startup from Midea Group (Fortune Global 500 Company).
  • They work on developing mobile robotic lawn mover and I have worked in Perception Team.
  • Developing robot simulations, perception system with NN & train in embedded systems for mobile robotics application
  • Design, implement navigation algorithms, setup experimental process & develop test scripts for robotics SLAM system
Website

Projects

Robot Learning

VLA Policy Training & Evaluation — SmolVLA

Tools: LeRobot, PyTorch, W&B, Isaac Sim, MuJoCo

  • Fine-tuned SmolVLA across PushT and LIBERO Spatial’s 10-task manipulation suite; monitored flow-matching loss, gradient norms, and closed-loop policy rollouts with W&B.
  • Built evaluation workflows across CALVIN, LIBERO, and RoboCasa, integrating policy inference, structured logging, and rollout analysis.
  • Enabled local training and evaluation within 8GB VRAM through batch-size tuning and memory configuration; implemented asynchronous inference and action-chunk aggregation to reduce execution jitter.

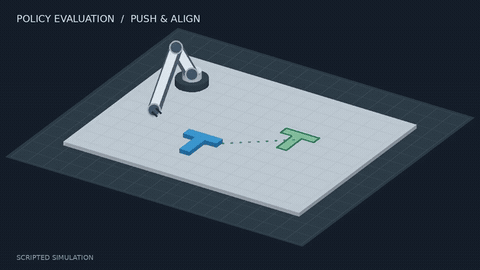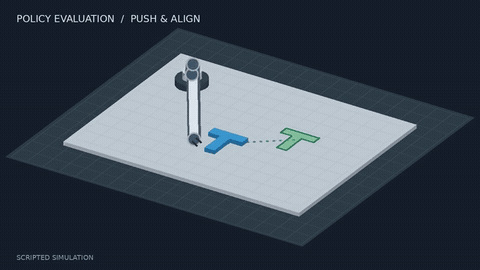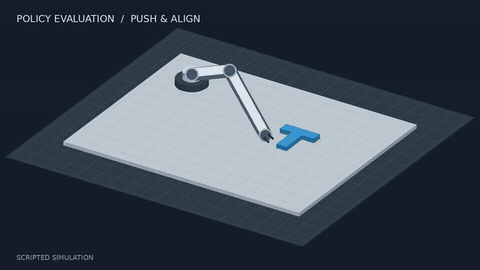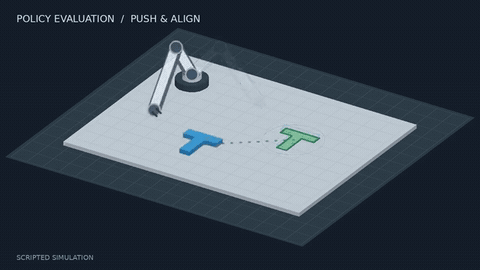
Illustrative policy-evaluation animation: robot pushing a T-shaped block to a target. Scripted visualization, not a recorded SmolVLA rollout. GIF ↗

Policy Evaluation & Debugging

SmolVLA Pick-and-Place & Sim-to-Real Debugging

Tools: PyTorch, LeRobot, Sim-to-Real Evaluation

  • Evaluated pick-and-place policies on cubes, cylinders, tetrahedra, and octahedra; diagnosed orientation-sensitive alignment and insertion failures on harder shapes.
  • Fine-tuned and debugged with targeted demonstrations and recovery data, adjusted observations for camera mismatch, and shortened action execution horizons for more frequent replanning near insertion.

SmolVLA reference manipulation demo · not my shape-sorting rollout. Source ↗

Demonstrations → Policy Learning

Isaac Sim Franka: Teleoperation → Mimic → SmolVLA

Tools: Isaac Sim, Isaac Lab Mimic, LeRobot, PyTorch, HDF5

  • Teleoperated a 7-DOF Franka Panda in Isaac Sim using keyboard SE(3) control to collect cube-to-bin demonstrations through Isaac Lab’s record_demos pipeline.
  • Expanded demonstrations with Mimic’s subtask-aware replay and pose randomization, converted HDF5 data to LeRobot format, and fine-tuned SmolVLA on an L40S GPU.
  • Closed the loop by evaluating the checkpoint with policy inference back in the same simulation scene.

MimicGen reference simulation · not my Isaac Sim rollout. Source ↗

DEC 2020 - JAN 2021

TurtleBot Navigation using DQN

Tools: Python, PyTorch, CUDA

  • Implemented DQN and Dueling DQN in PyTorch with experience replay and target networks for navigation with LiDAR observations.
  • Designed reward shaping around goal heading, distance, obstacle proximity, and goal/collision outcomes; trained in Gazebo and deployed the learned policy to a physical TurtleBot.
Code

Illustrative TurtleBot-style simulation with moving obstacles; scripted visualization, not a recorded DQN or Gazebo rollout. GIF ↗

June 2020 - July 2020

TurtleBot Path Tracking using PID Controller

Tools: ROS, Gazebo, C++

  • Hardware and software implementation of Turtlebot path tracking system using PID controller
  • Experimented on single and multi-goal points determining steering control at each instant of time while navigation
Report Code Video

Original project demonstration. Source ↗

Imitation Learning

Behavior Cloning for Autonomous Driving

Tools: CARLA, TensorFlow, Keras, GPU

  • Generated real-time demonstration data and trained a CNN to clone ego-vehicle driving behavior in CARLA.
  • Built an end-to-end imitation-learning workflow from demonstration collection to policy deployment.

My behavior-planning simulation · related AV project footage. Source ↗

Robotics project demonstration

Feb 2020 - May 2020

Shared Autonomy in Motion Mapping Teleoperation

Tools: ROS, Python, OpenCV, Gazebo

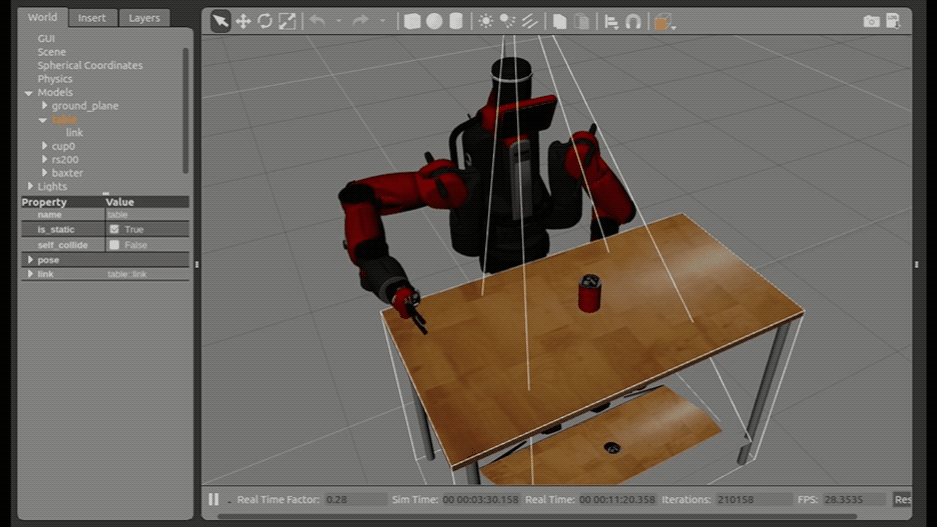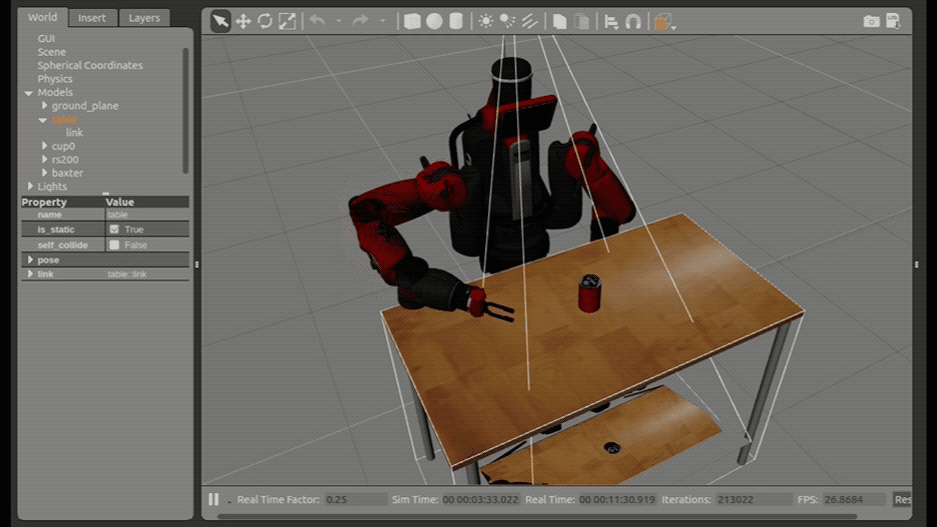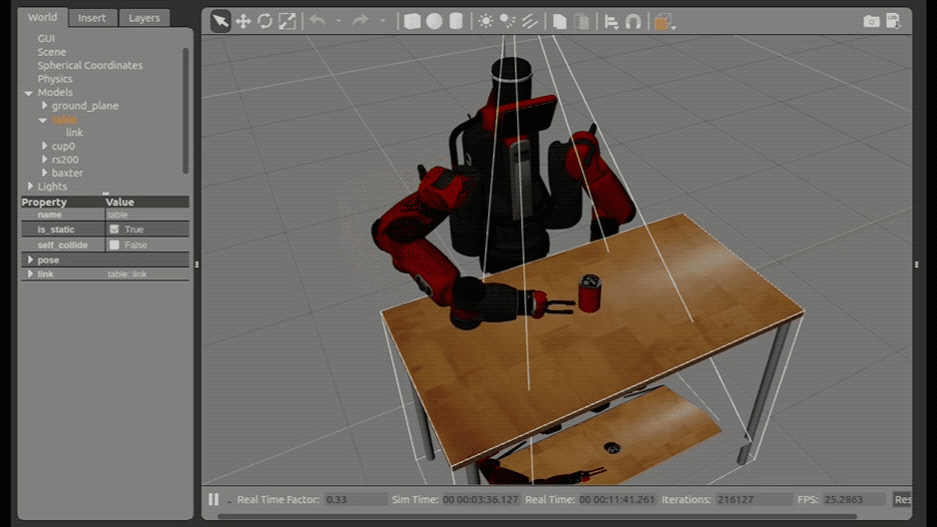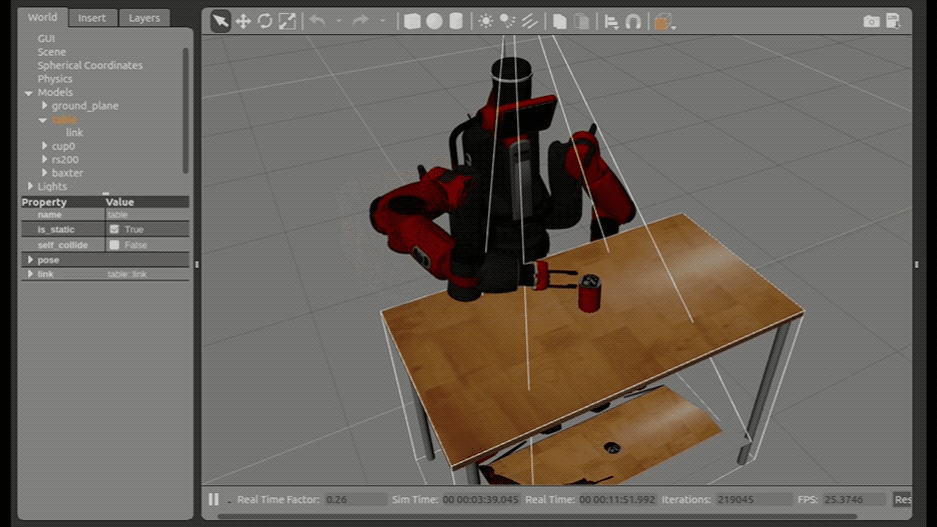
  • Implemented Autonomous, Semi-Autonomous functions for moving 7 DOF Baxter robot arms in ROS and designed gazebo environment
  • Created ROS Nodes to build Meshed, Cone and Take Control Methods that works the Semi-autonomous function reducing human fatigue while teleoperation
  • Programmed Aruco Marker detector for identifying cups in gazebo environment using OpenCV bridge
Report Code
Robotics project demonstration

Sep 2019 - Dec 2019

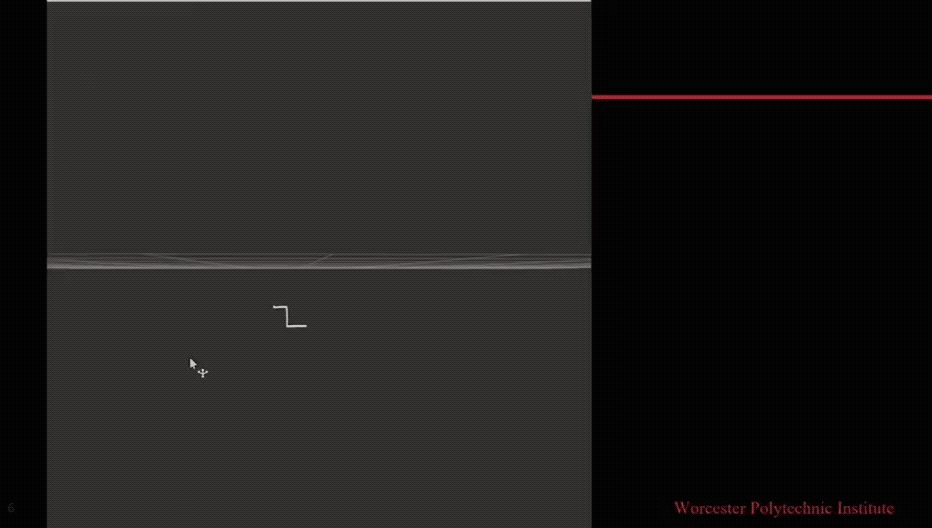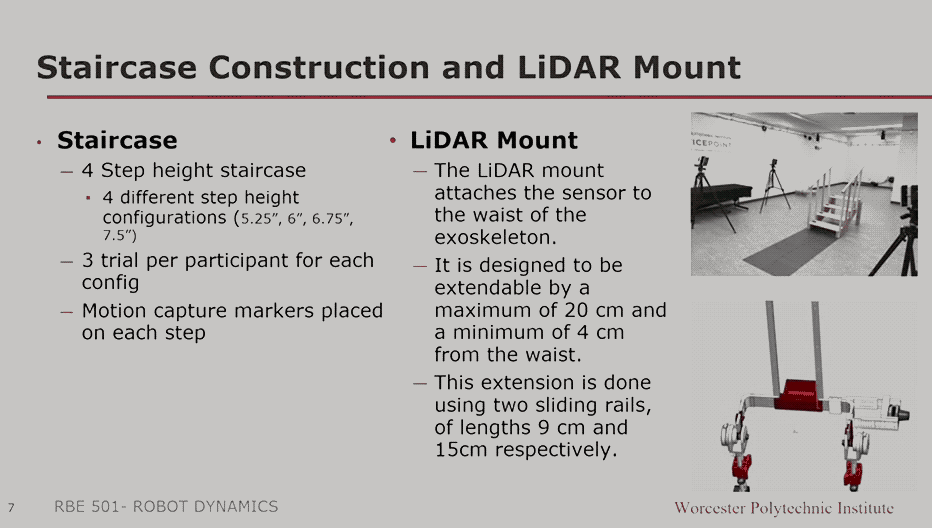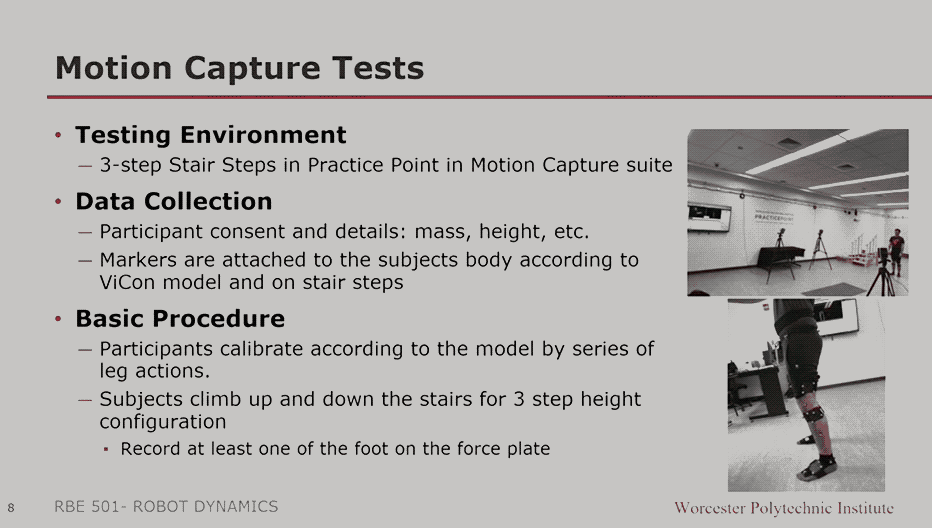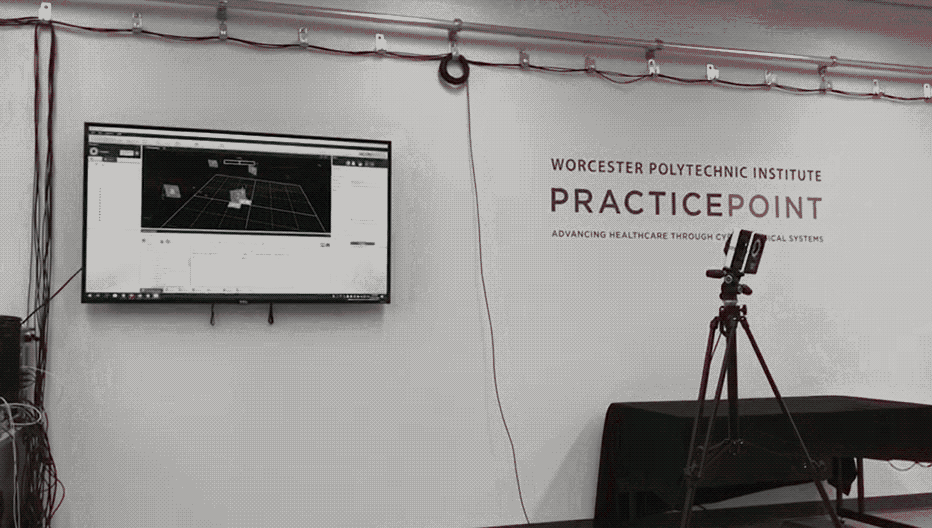
Dynamic Step planning for Exoskeleton Stair Climbing

Tools: ROS, Gazebo, PCL, C++, Python, Solid Works

  • Implemented simulation environment of Lidar laser scan and published its data in Point cloud using ROS and Gazebo
  • Investigated DMPs and assisted to train the DMPs generating trajectories for determined joint angles
  • Implemented path planning approach algorithm for stair climbing and generating step trajectories
  • Operated Motion capture lab to collect the gait data of 15 subjects using Vicon Nexus for generating joint angles
  • Worked on LiDAR data acquisition, line segmentation of point cloud data using RANSAC and visualization of staircase using ROS
Report Code Video
Robotics project demonstration

March 2020 - May 2020

Indoor 3D mapping using RGBD camera

Tools: ROS, Gazebo, C++

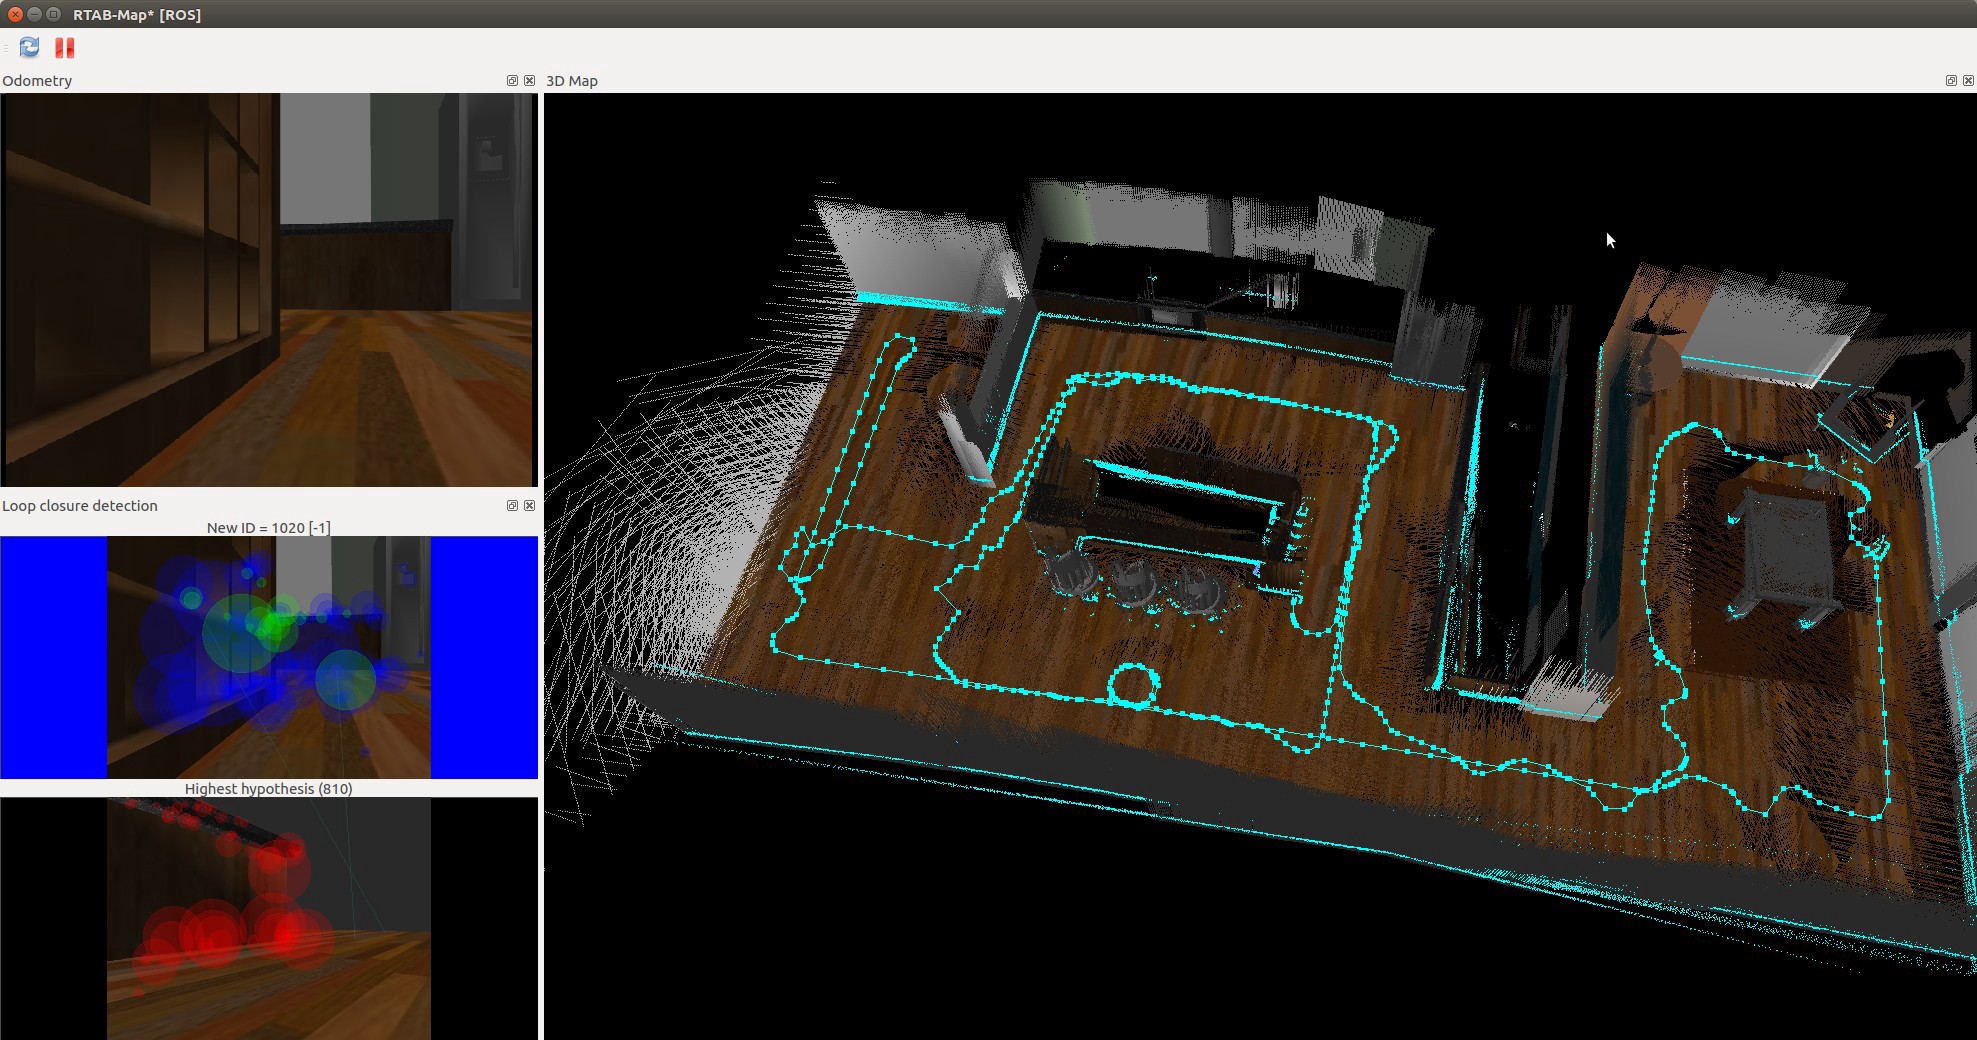
  • Implemented the state-of-the-art RGB-D SLAM algorithm for 3-D map building of indoor spaces
  • Generated 2D occupancy grids and 3D point cloud data while navigating mobile robot in gazebo using RTAB mapping
Report Code Video
Robotics project demonstration

June 2020 - July 2020

OpenStreetMap-based Route Planner

Tools: OSM, C++

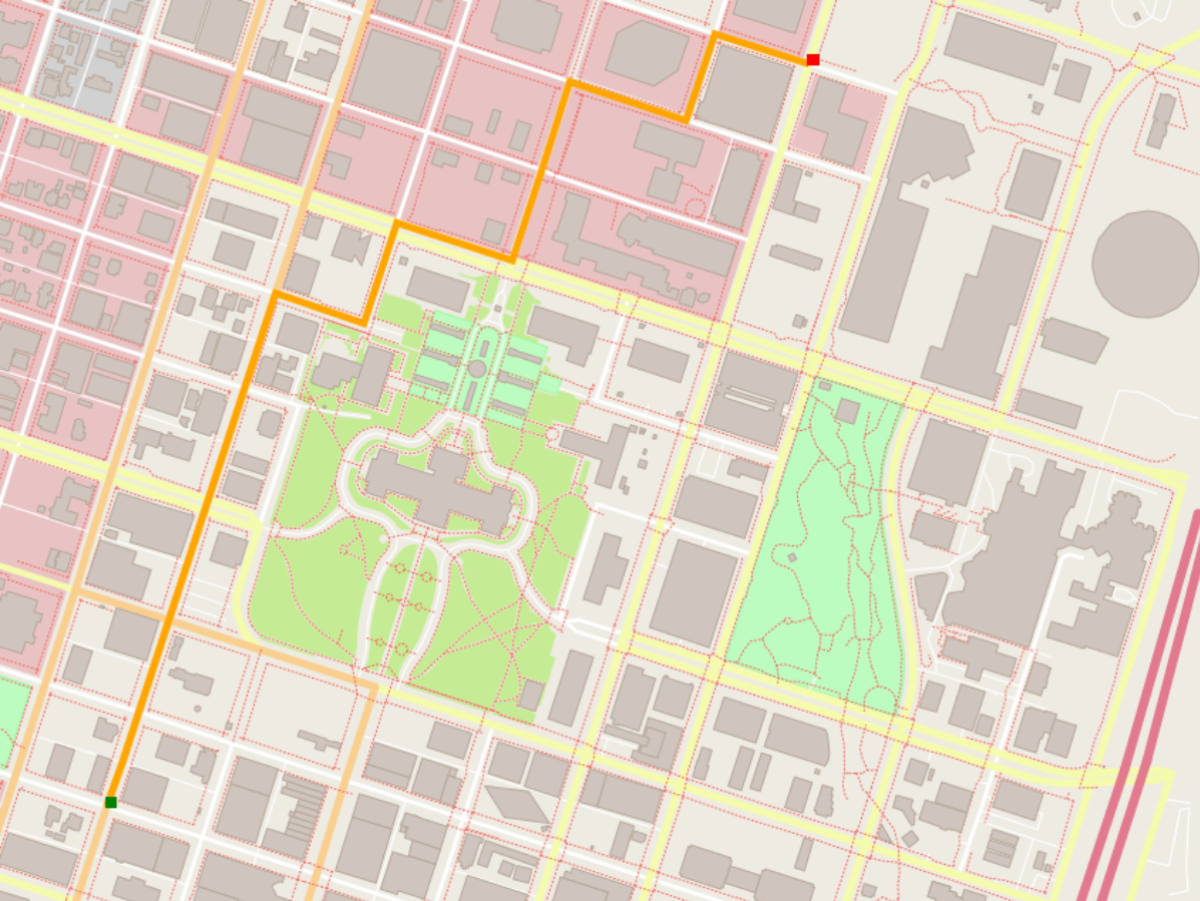
  • Constructed a Route Planner based on A* algorithm on the OpenStreetMap framework.
  • Developed the project using the IO2D library with C++14 on linux based system
Code
Robotics project demonstration

March 2020 - May 2020

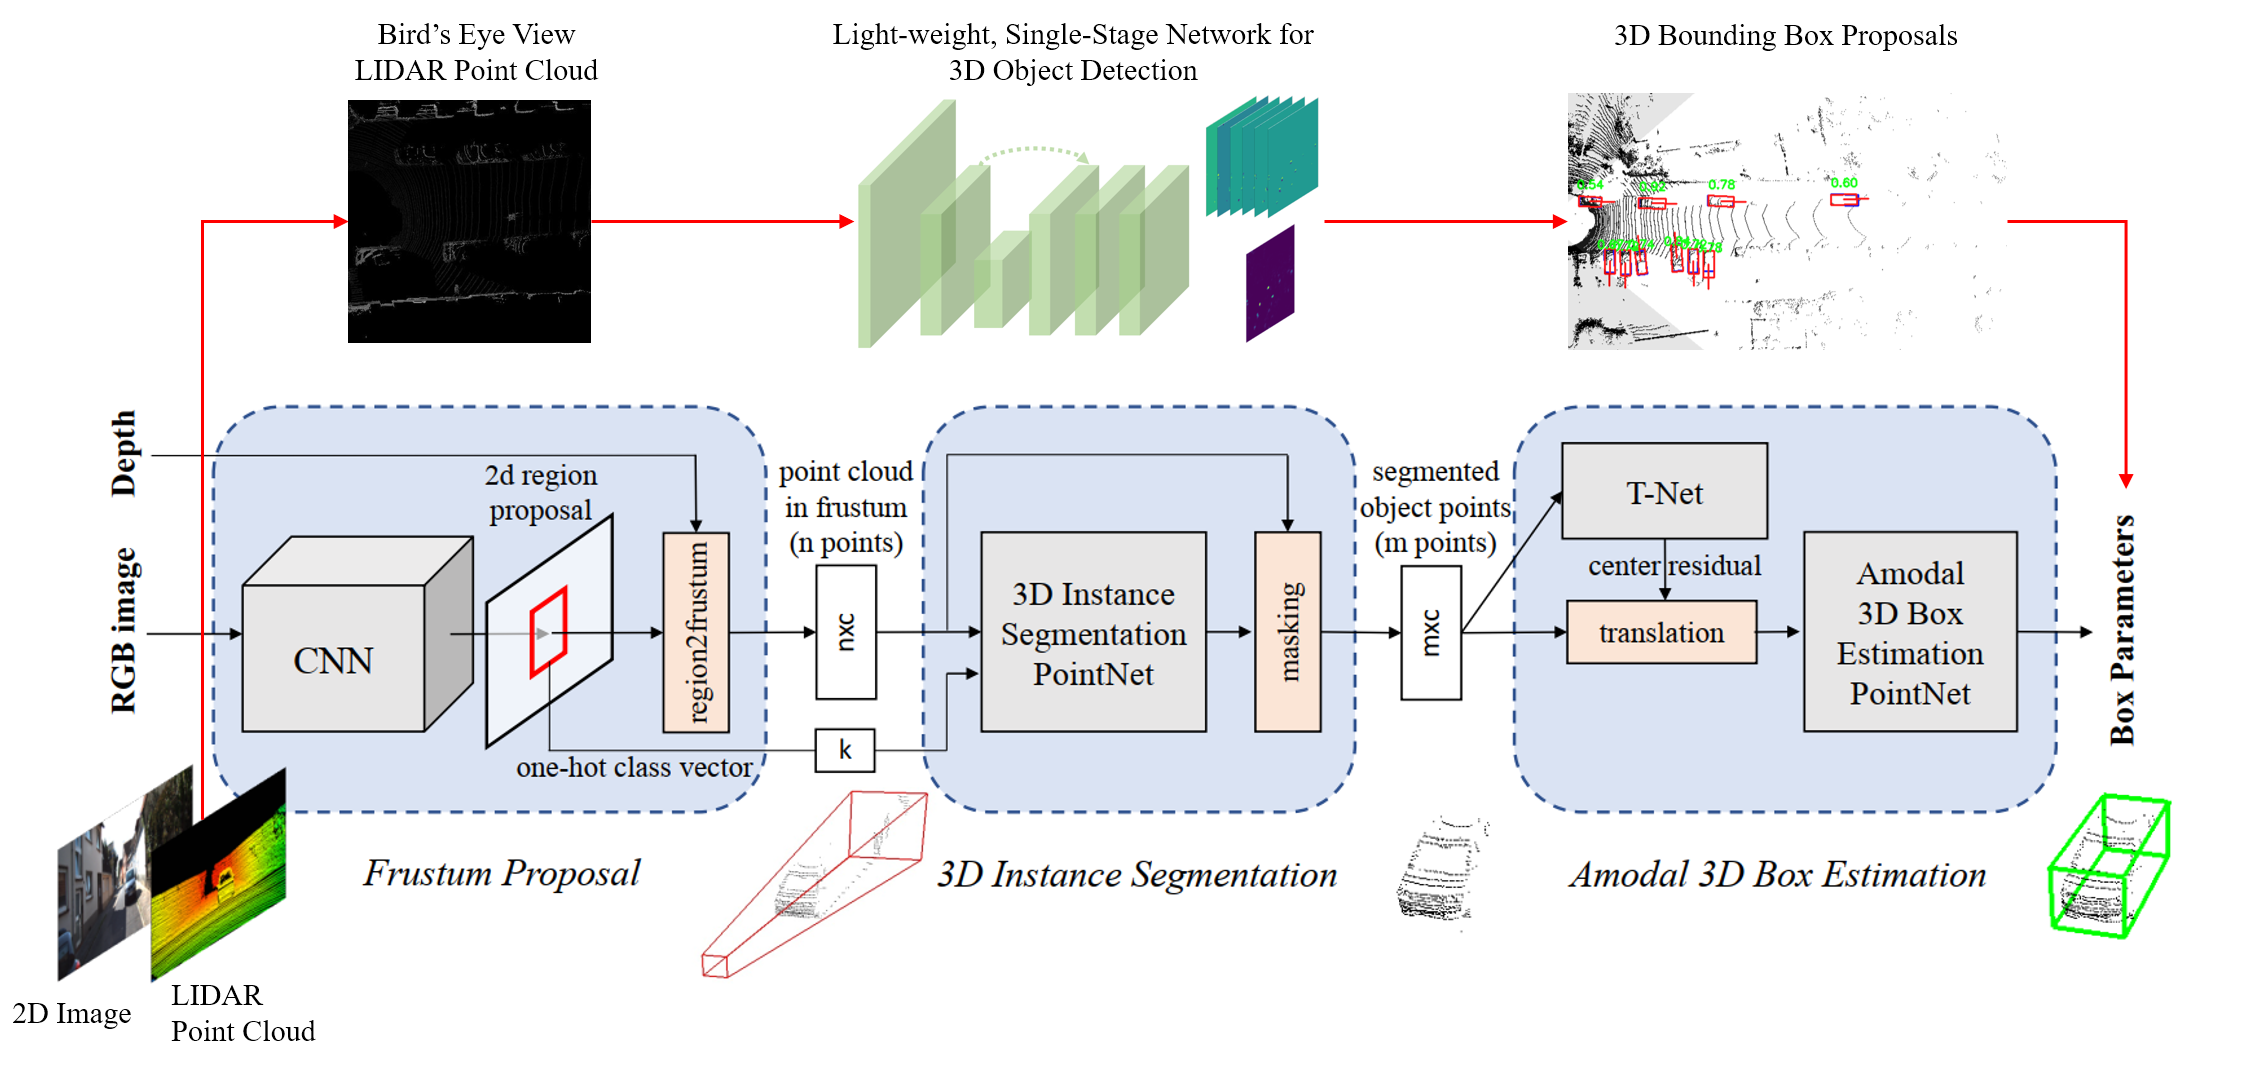
3D object detection using Modified Frustum PointNets

Tools: Python, Tensorflow, GCP console

  • Performed 3D object detection on the KITTI dataset with the goal of reduced computation time and accuracy
  • Experimented with using SqueezeDet in Frustum PointNet architecture for 2D detection instead of fine-tuned Fast R-CNN
Report Code
Robotics project demonstration

Oct 2019 - Dec 2019

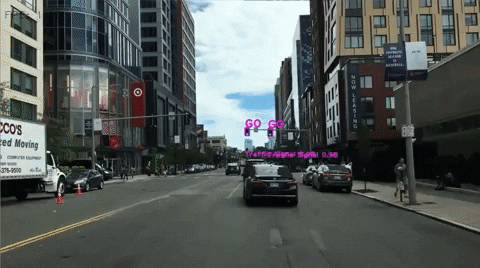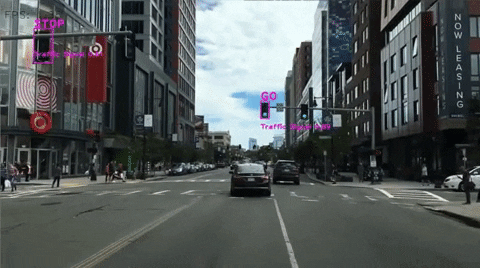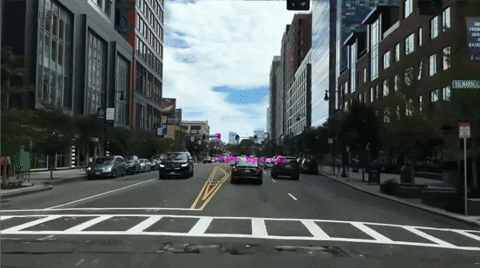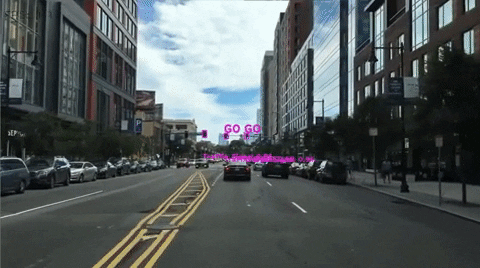
Traffic Signal Detection System

Tools: OpenCV, Python

  • Extracted image features using SIFT & SURF, Hough transforms, Top-hat filter algorithms compared statistically with YOLOv3
  • Integrated Darknet YOLOv3 Deep Neural Network for robust real time object detection and SVM for status recognition
  • Built an HSV Classifier for real-time classification of Traffic Lights for Autonomous Vehicles
Report Code Video
Robotics project demonstration

June 2020 - July 2020

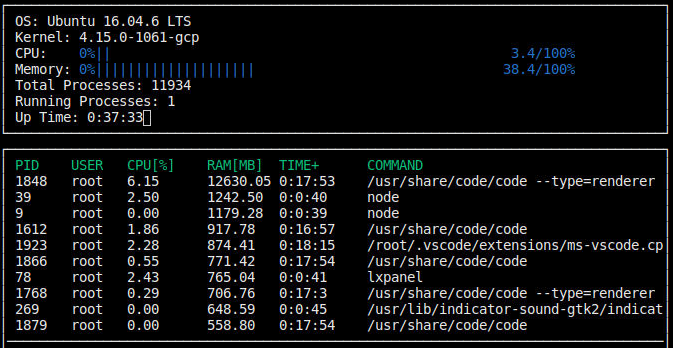
Linux-based System Moniter

Tools: C++, Linux

  • Implemented a system monitor to track the cpu utilization, ram usage, activity time and base-command.
  • Compatible with all Ubuntu Distributions, tested on Ubuntu 16.04 and Ubuntu 18.04
  • Based on Object Oriented Programming using C++14
Code

Research

Robotics project demonstration

September 2020 - Dec 2020

Behaviour planning for autonomous vehicles

Tools: MATLAB, Simulink, C++

  • Worked with Prof. Xiangrui Zeng for creating a behaviour planner and extending on CARLA
  • Implementing behaviour prediction engine with MPC controller and Integrating Sensor fusion modules to detect multi agents
  • Determining cost functions to create constraints for decision making module in Lane changing task with MIOs
  • Evaluating Motion Metrics for collision detection in Simulink using stateflow diagram and triggering decision to change lane.
Report Git
Robotics project demonstration

September 2020 - May 2021

Collision avoidance in dynamic environment using velocity obstacles

Tools: ROS, Gazebo, C++, Kalman filter, AMCL, Eigen, OpenCV

  • Worked at Human-Inspired Robotics(HIRo) Lab with Prof. Zhi Li on Velocity Obstacles method ORCA (Optimal Reciprocal Collision Avoidance) algorithm
  • Implementing state of the art method ORCA for social aware navigation of freight robot in hospital environment
  • Modelling & Integrating human and obstacle tracking modules for Multi-Human and robot Collision avoidance detection.
  • Integrating RVO2 libraries into ROS environment and tunning & testing ORCA hyperparameters for robust navigation
Report Code Video

Jan 2019 - May 2019

Research Assistant at University of Plymouth, UK

Tools: MATLAB, C++, Openvibe, LSL, psychtoolbox, Chestnut PCB

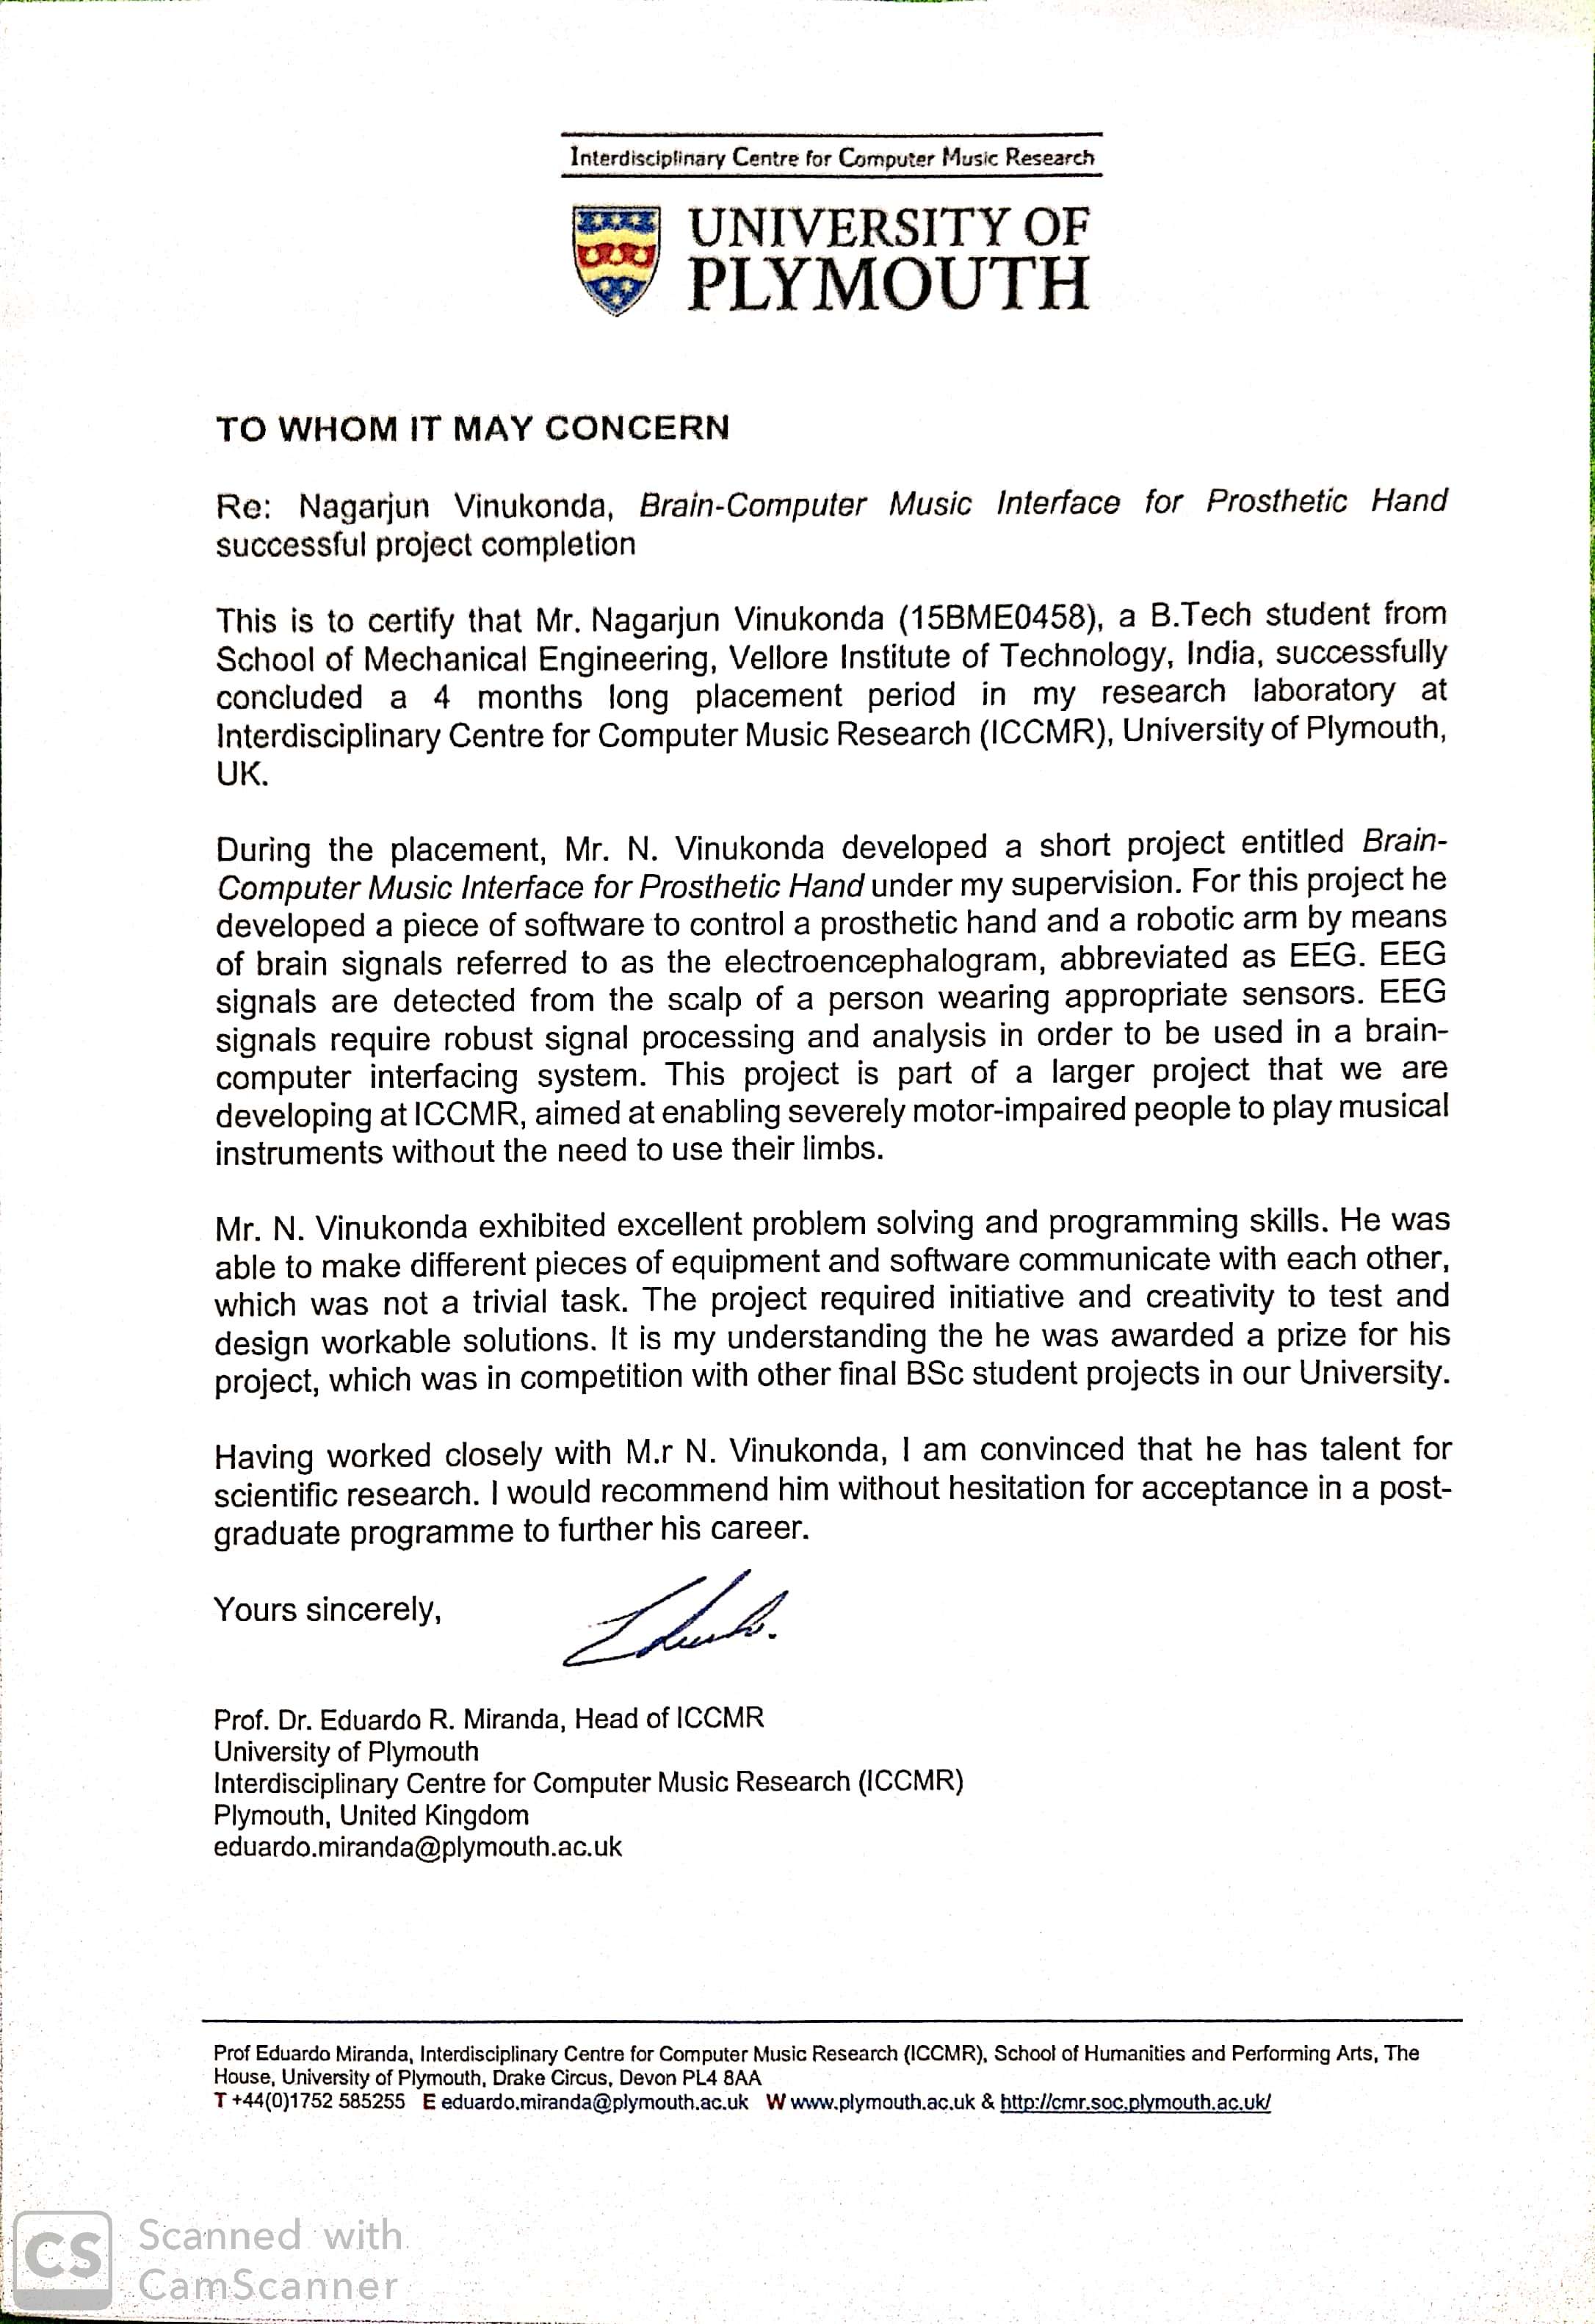
  • I am advised by Prof.Eduardo Miranda to extend Research on Computer-Music with Robotics
  • Developed a BCMI system that enables people with severe motor impairment to play music using prosthesis
  • Programmed and modelled an integrated system that maps visual evoked potentials obtained to Brunel hand using MATLAB
  • Analysed EEG signals in Openvibe and implemented noise filters using digital signal processing methods
  • Researched and implemented Canonical Correlation Analysis algorithm to compute real-time mapping of EEG signals
Paper Git Letter of Recommendation Video

Original project demonstration. Source ↗

Earlier Internships

Robotics project demonstration

May 2017 - June 2017

Industrial Intern: VEM Technologies Pvt.Ltd., Hyderabad, India
  • Educated and exposed on the working mechanism of Section 3 of surface-to-air Akash missile and Brahmos missile, Electro-Optical Director, Stabilized Electro-Optical Sight and wash timers
Certificate
Robotics project demonstration

June 2017 - July 2017

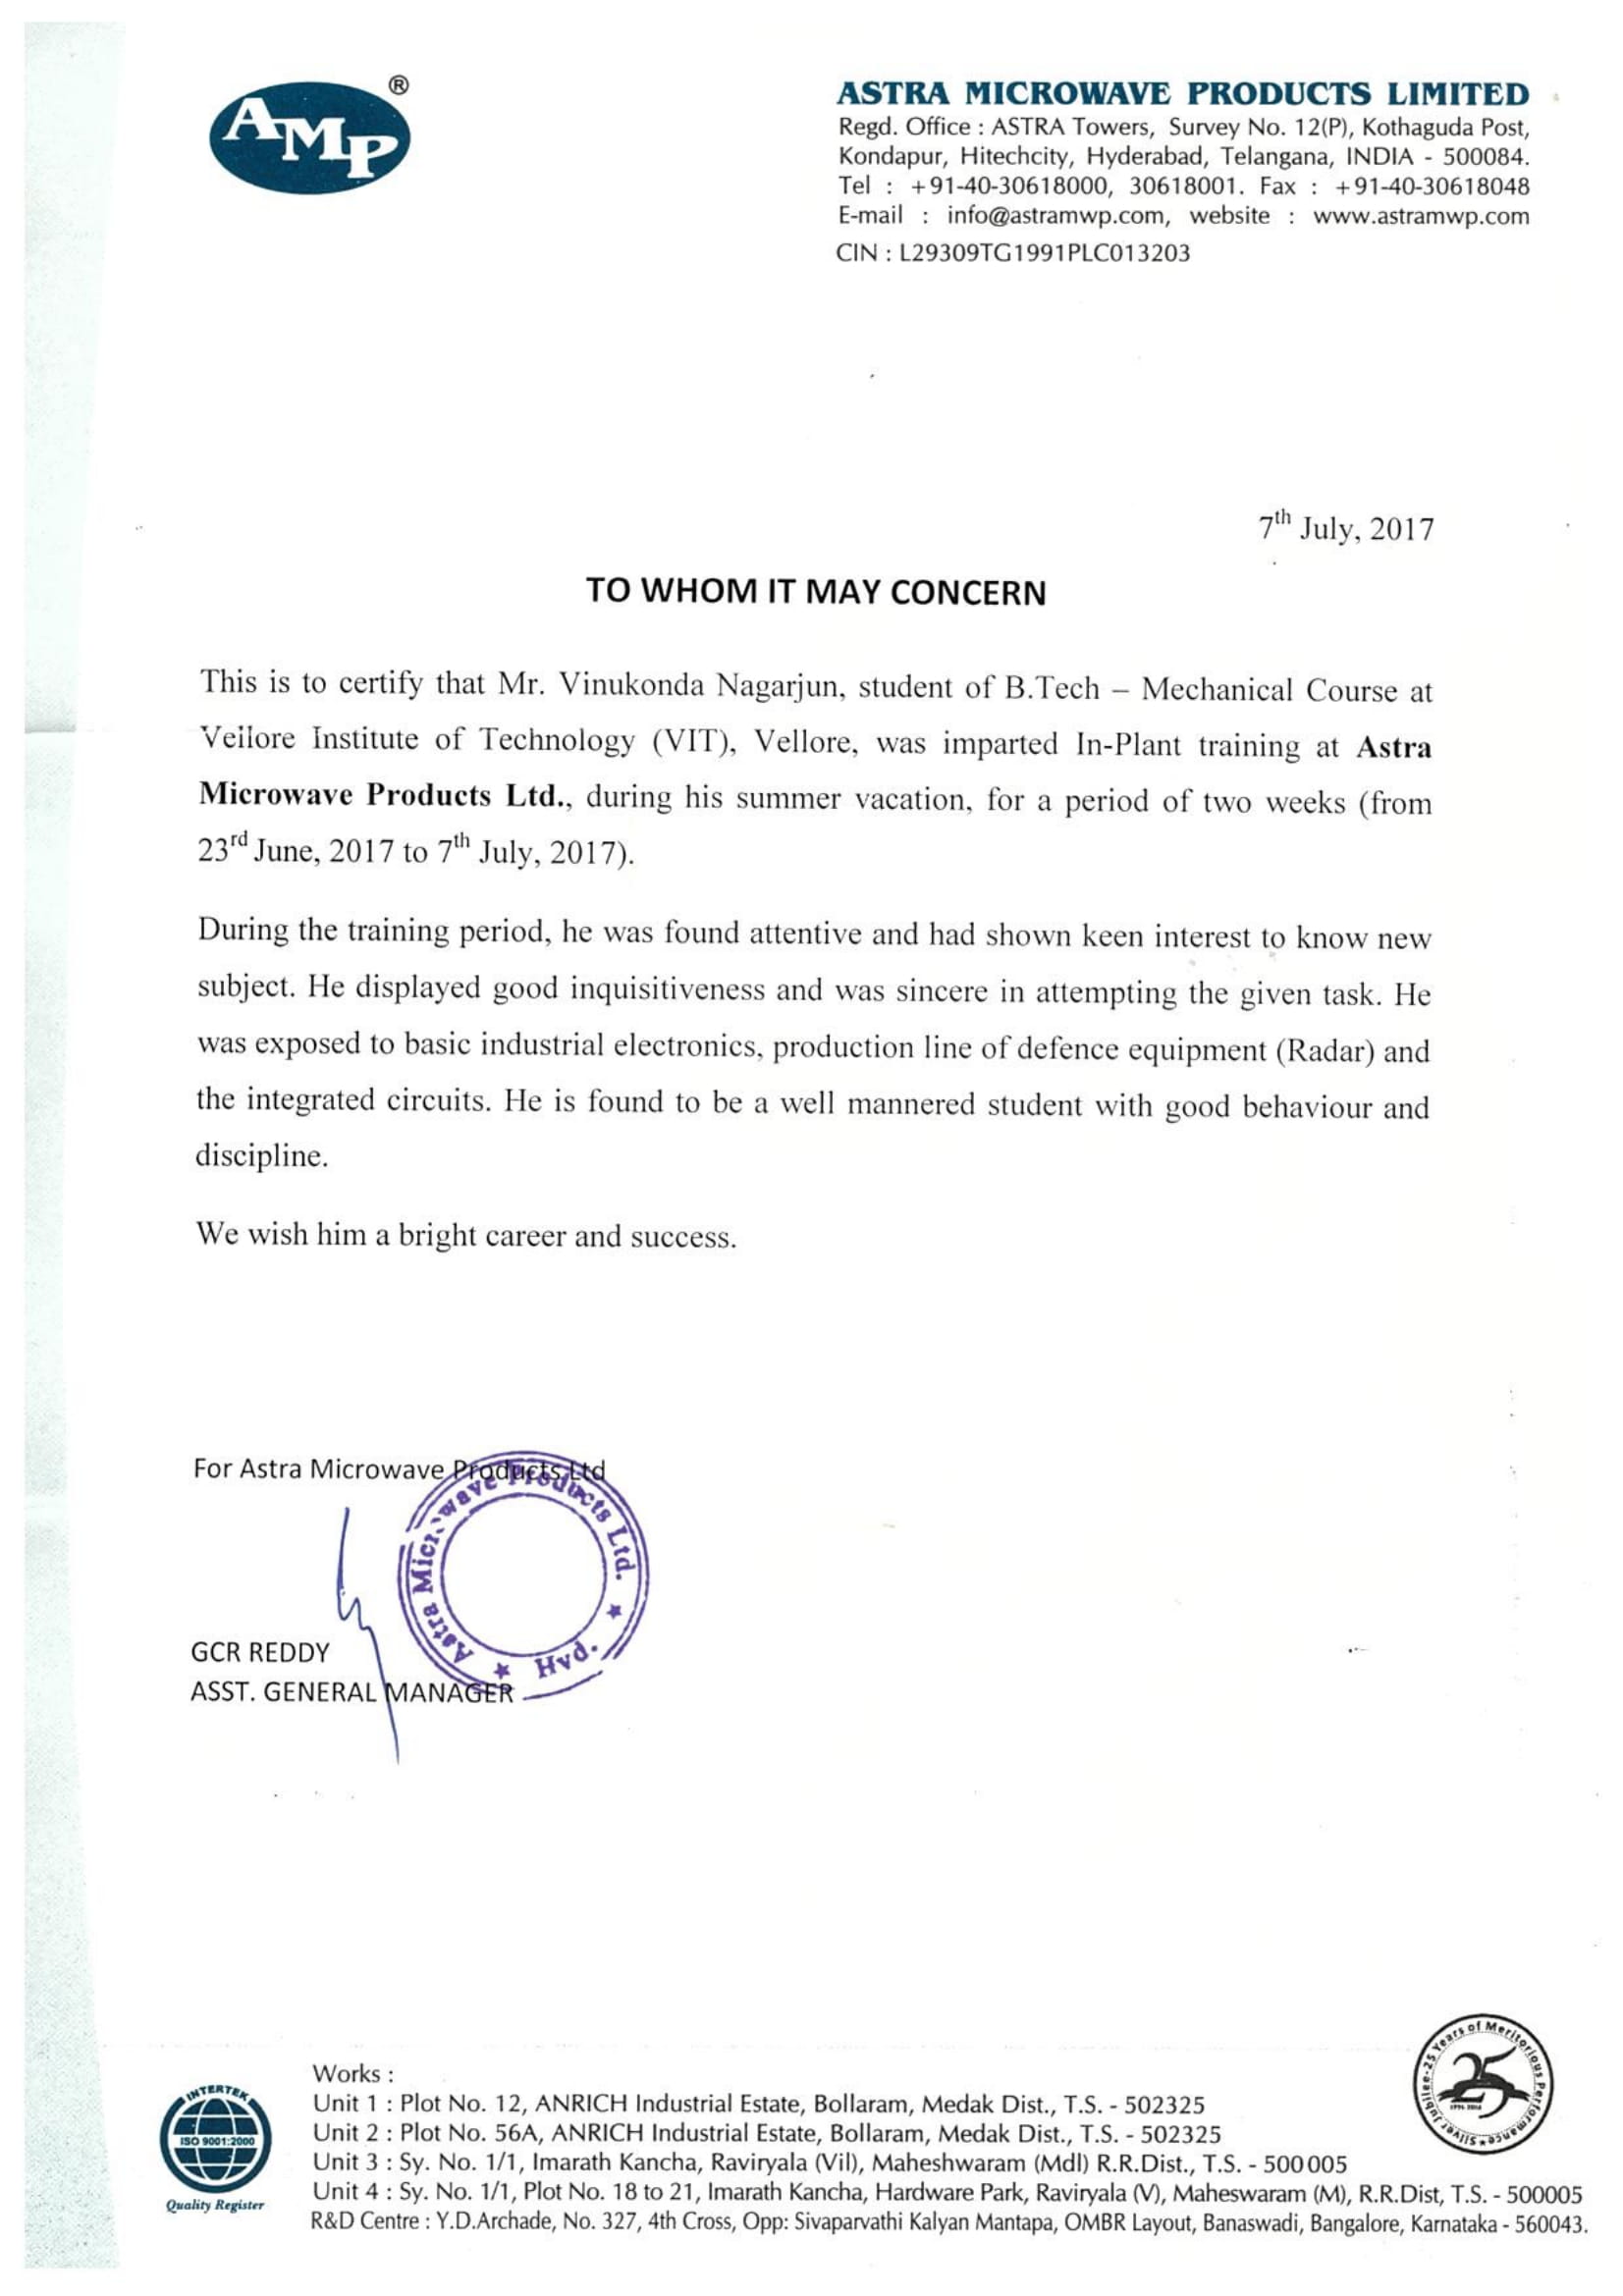
Industrial Intern: Astra Microwave Products Ltd., Hyderabad, India
  • Exposed to work mechanisms of pressure sensors used in power window system along with integrated circuits of radars and industrial electronics
Certificate

Publications

Robotics project demonstration

December 2018

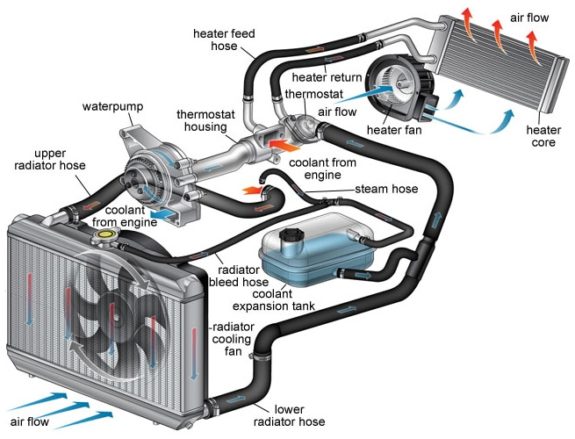
Review on Contemporary Trends in Radiator Design and Testing of Automobile Radiators
  • Published at International Journal of Mechanical Engineering & Technology, ISSN Online: 0976 – 6359, Vol.9, Issue 12, December 2018
  • The paper presents various methods to improve automobile radiators efficiency and testing methods to validate the performance of radiators
Paper

Achievements

Robotics project demonstration

May 2019

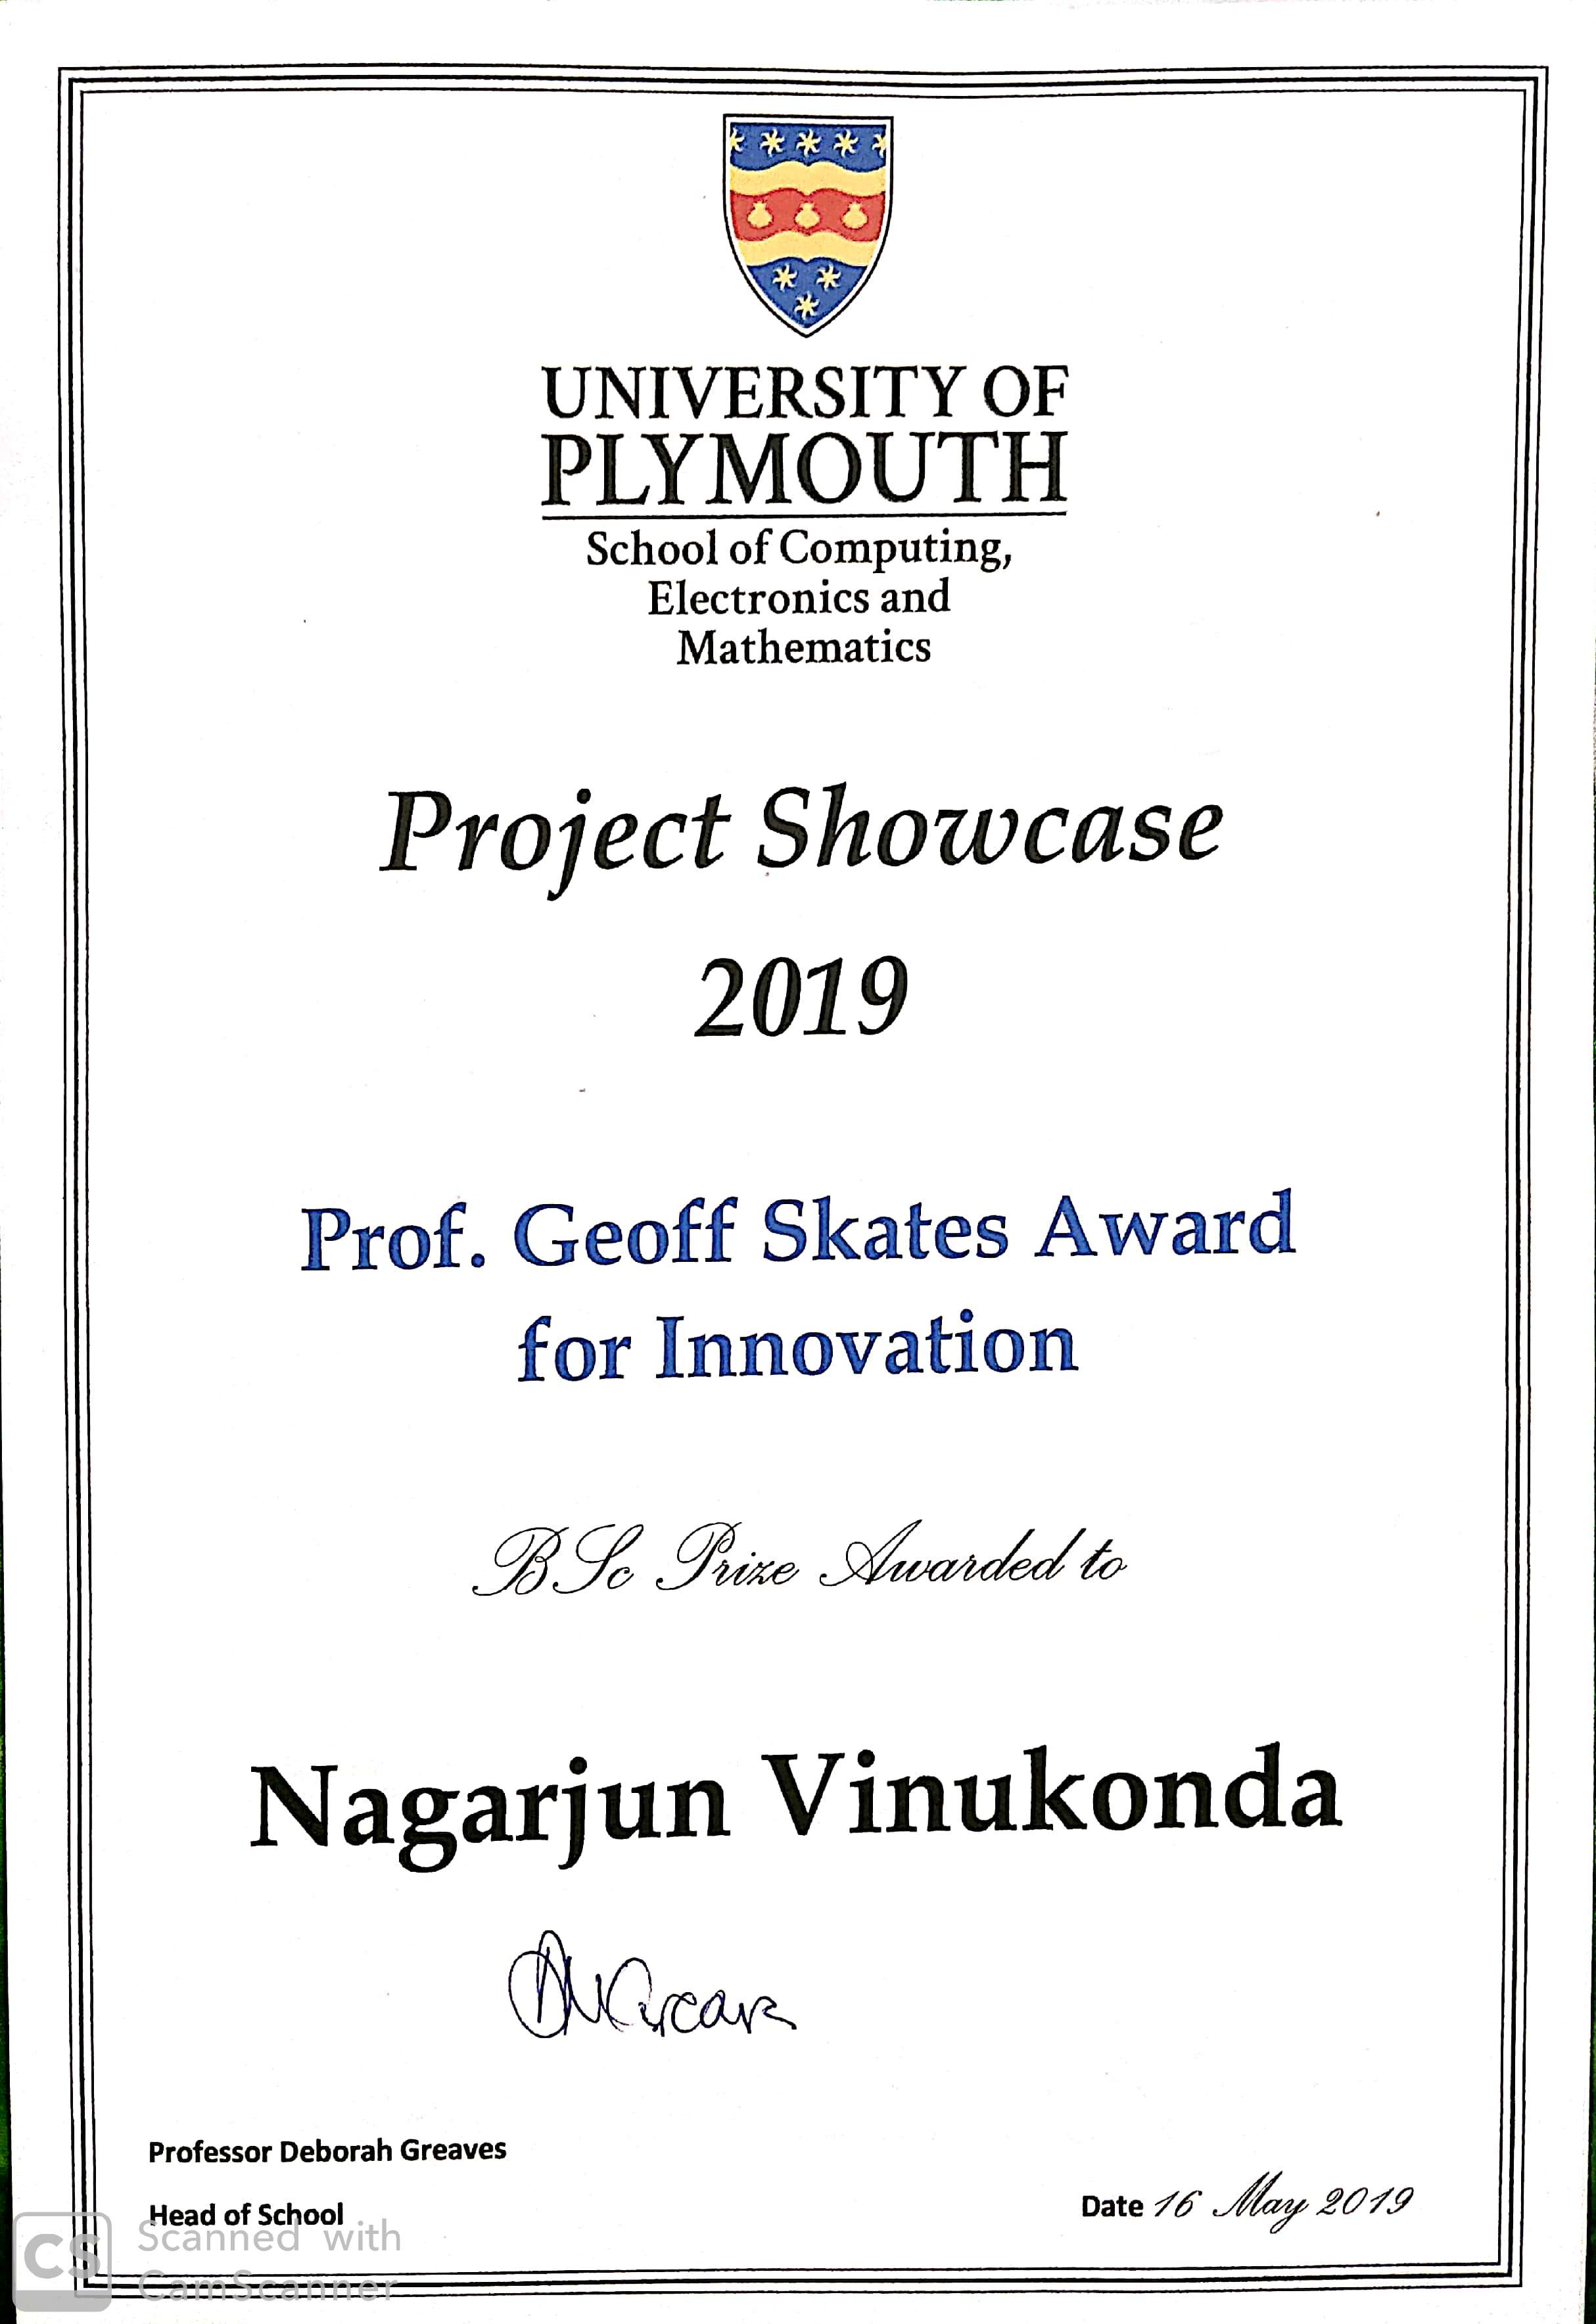
Project show case: Award for Innovation, University of Plymouth
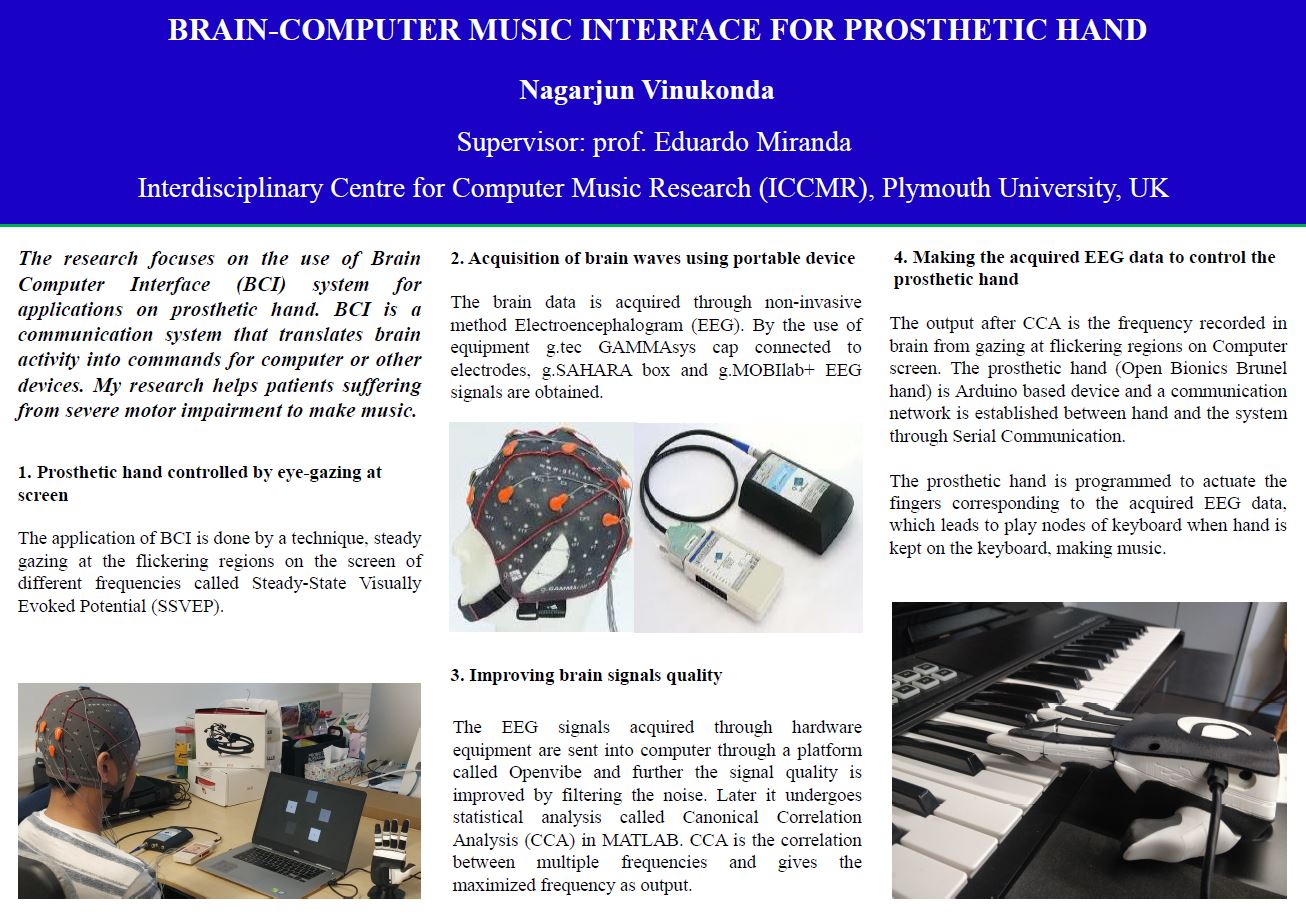
  • To study BCI methods and develop a real-time integrated system that connects brain waves to prosthetic arm enabling severe motor impairment patient to play musical instruments using prosthesis
Certificate Poster
Robotics project demonstration

9-11 March 2018

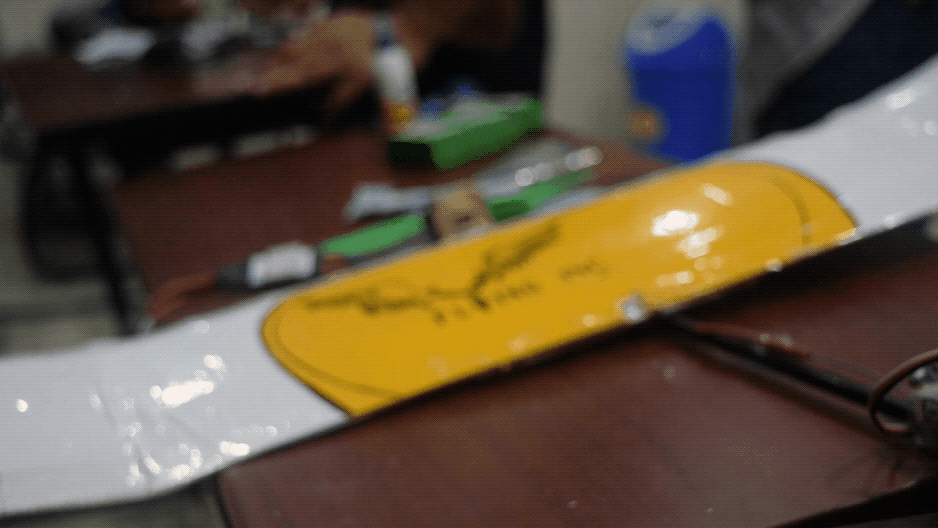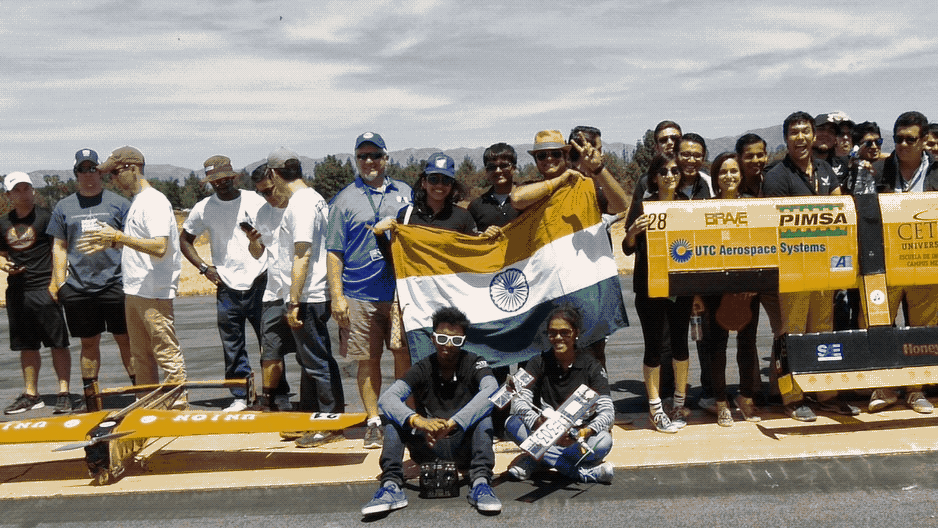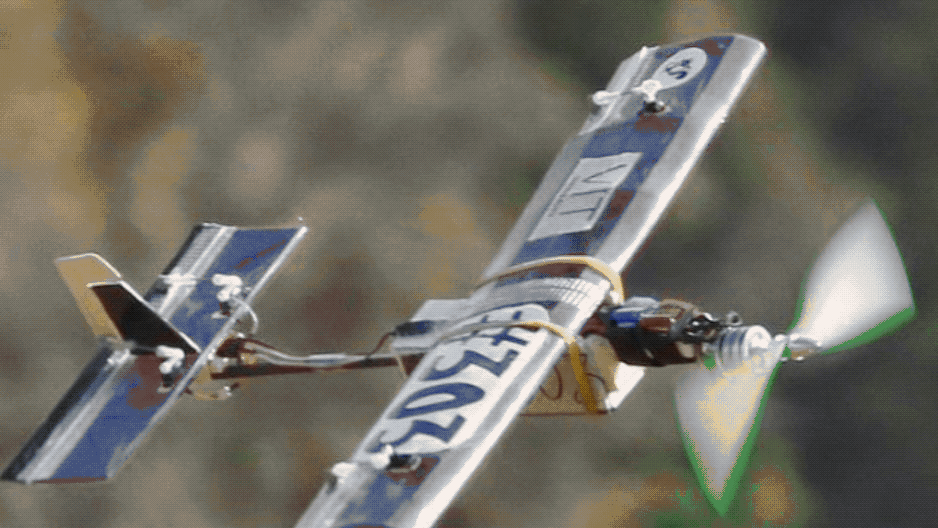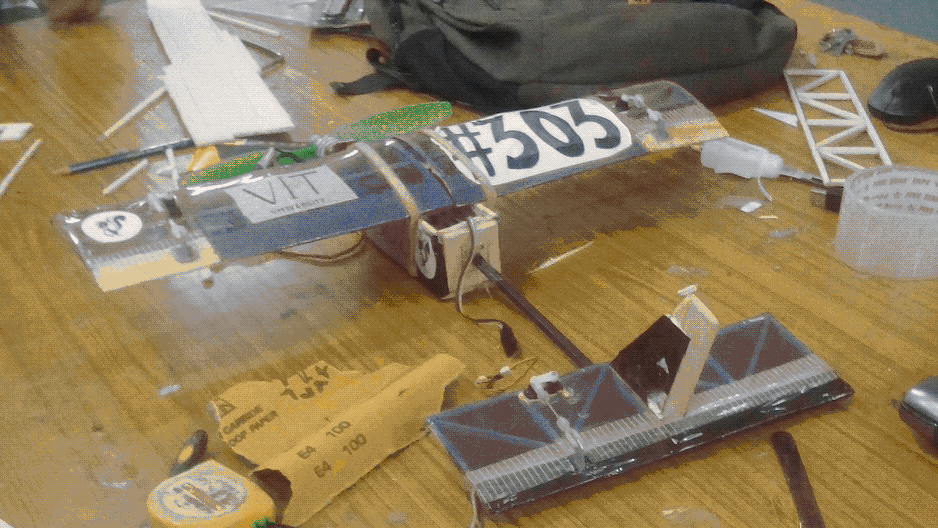
SAE Aero-Design International competition, Florida, USA
  • Competed at Lockheed Martin Aeronautics Co. Lakeland, as Vice-Captain of Team: Aero-VIT -- Regular Class: Aero-design competition
  • Design of 144 inches wingspan aircraft, 18lbs payload capacity for carrying 24 passengers (Tennis balls).
  • Implemented algorithm for prediction of lift and drag using Simulink along with Structural and fluent analysis of aircraft using Ansys
  • Establishing successful test flight along with participation in competition securing second position in Asian-pacific region.
Certificate
Robotics project demonstration

11-13 July 2018

SAE Aero-Design National competition, India, Chennai
  • Competed at Anna University, as Vice-Captain of Team: Flying Inc. -- Micro Class: Aero-design competition
  • Design and Analysis of 36 inches wingspan radio-controlled aircraft with successful flight test and participation in competition
Certificate

Licenses & Certifications

Robotics project demonstration

January 2019

Motion Planning for Self-Driving Cars - Coursera
  • The course focuses on main planning tasks in autonomous driving, including mission planning, behavior planning and local planning.
  • Implemented hierarchical motion planner to navigate through a sequence of scenarios in the CARLA simulator: Avoiding static vehicles, following a lead vehicle and safely navigating an intersection.
  • Calculated time to collision(static), computed velocity profiles, designed state machine that transitions between lane following, deceleration to the stop sign for safe navigation.
  • Generated occupancy grid using lidar scanner measurements, iteratively constructed a probabilistic occupancy grid from log odds updates.
Document Confirmation Link
Robotics project demonstration

January 2019

Control of mobile robots - Coursera
  • The course Control of Mobile Robots focuses on the application of modern control theory to the problem of making robots move around in safe and effective ways
  • As part of course I have wroked on implementation of project strutctre in Simulink for calculating angular speed of left and right wheel with odometry and wheel encoders, PID regulator.
Document Confirmation Link
Robotics project demonstration

February 2019

Machine Learning - Coursera
  • Got broad idea of Machine Learning Algorithms, Unsupervised and Supervised learning, bias/variance theory, SVM's and numerous case studies and applications of learning algorithms to build smart robots (perception, control), Computer Vision and other areas.
Document Confirmation Link
Contact Me
Get in Touch!

Address

San Francisco, California, USA